
Number 1:  Formato24
Open source tools for website audits and React Native chat integration
- Open Source
- Italy
- DR 0 no change since last check
Open Source
Open-source multi-visual-inertial sensor calibration toolbox and benchmark
Ahrefs Domain Rating benchmarked 15 Nov 2026, rebuilt 15 Nov 2026.
A Python toolbox and public benchmark for calibrating multi-camera, multi-IMU sensor rigs with support for rolling shutter, multiple projection models, and
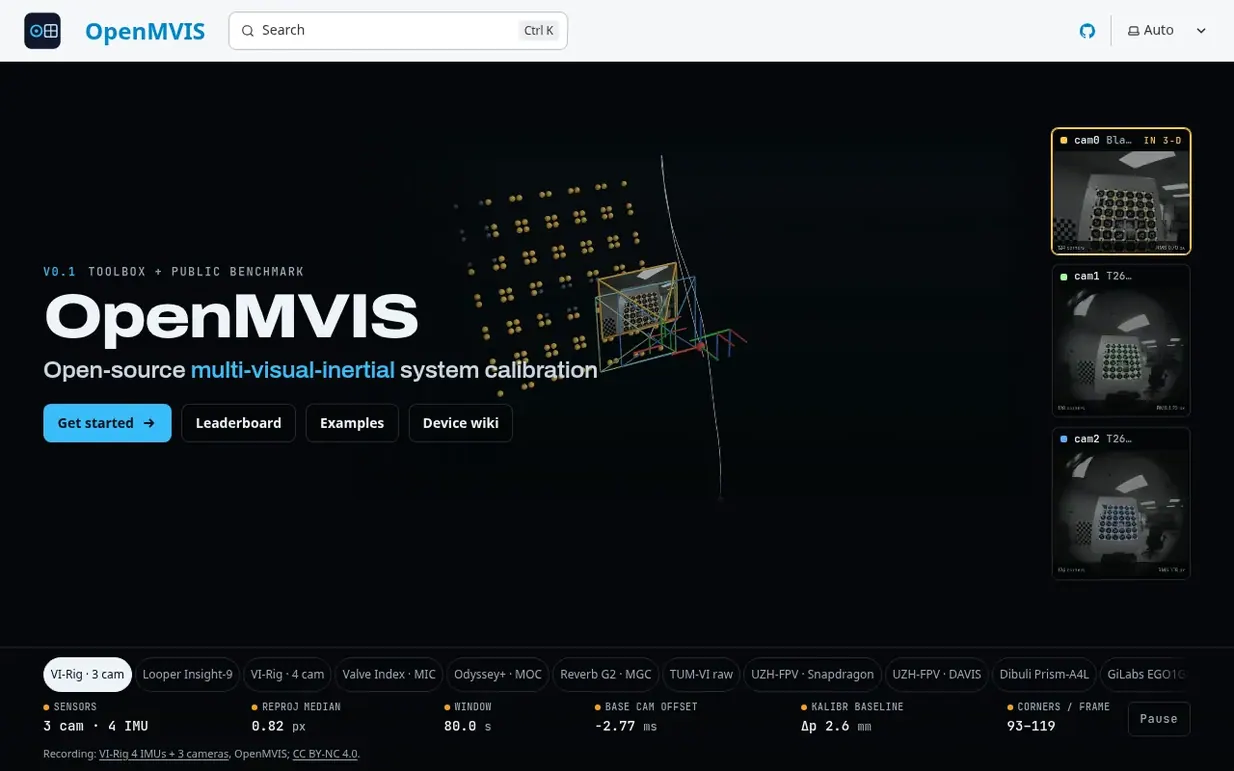
OpenMVIS is an open-source toolbox (MVIS) and benchmark (Calibench-VI) for multi-visual-inertial sensor calibration. It calibrates camera intrinsics, distortion, extrinsics, time offsets, rolling-shutter readout, board poses, camera-IMU transforms, and IMU parameters in a single factor graph optimization.
The toolbox handles capabilities that competing tools like Kalibr and Basalt do not: rolling shutter combined with IMU, mixed global and rolling shutter cameras on one rig, non-flat board shape estimation, gyro-to-accel time offset, digital-twin simulation, and round-trip verification without ground truth. It supports eight projection models including fisheye and omnidirectional cameras.
MVIS reads ROS1 and ROS2 bags, EuRoC folders, and image sequences. It produces self-contained HTML reports and integrates with Kalibr's configuration format. The benchmark includes public datasets from the VI-Rig, Looper, GiLabs, and other devices, with results validated against TUM-VI.
Pricing model: Open source
Following OpenMVIS means an email when they reach a milestone, post an update or launch a new product.
| Metric | Value |
|---|---|
| Domain Rating | 3 no change since last check |
| Trust Flow | 2 no change since last check |
| Citation Flow | 14 no change since last check |
| Referring domains | 3 no change since last check |
| External backlinks | 9 no change since last check |
Ahrefs Domain Rating benchmarked 15 Nov 2026, rebuilt 15 Nov 2026. Main build topic: Reference/Education (2). Majestic benchmarked 15 Nov 2026, rebuilt 15 Nov 2026. Link data built by Majestic. Trust Flow, Citation Flow and Topical Trust Flow are trademarks of Majestic-12 Ltd.
| Domain age | 3 years |
|---|---|
| Registered | |
| Expires | |
| Registrar | Squarespace Domains II LLC |
| DNSSEC | Signed |
Plan your launch with our free playbook, from preparing your listing to choosing more launch directories.
Nobody has put OpenMVIS on the bench yet. Leave the first review.
Reviewing is free, and nobody can pay for a review. Read the bench notes
Maker reviews · Workshop notes · Show it off · Did you make this? Claim it · Report this build
OpenMVIS has a free listing. The owner can unlock the full profile with a paid launch for $5:
Formato24Open source tools for website audits and React Native chat integration
 bridgewatch
A tray monitor for GitLab CI and GitHub Actions
 FlyItalyADSB
Global community network tracking aircraft using ADS-B and MLAT technology
A programming language based on 1980s hard rock and power ballad lyrics